Skip to content
SJA RoboticsATIANA Virtual LabSJA Robotics

SJA Robotics · SJA Inc.

The ATIANA Virtual Lab

ATIANA is a planned, approximately six-foot, human-looking humanoid robot. Its hands, arms, vision, coordination core and the ATIANA Mini desktop platform are developed as independent projects. This lab brings them together, and you can try their public browser simulations here.

Subsystems
5
Public simulations
4
Hardware-validated
0

Subsystems

Five projects, one robot

Each Explore button opens that project's own public simulation in a new tab. A button is enabled only when the project documents a public deployment and it was reachable when last checked.

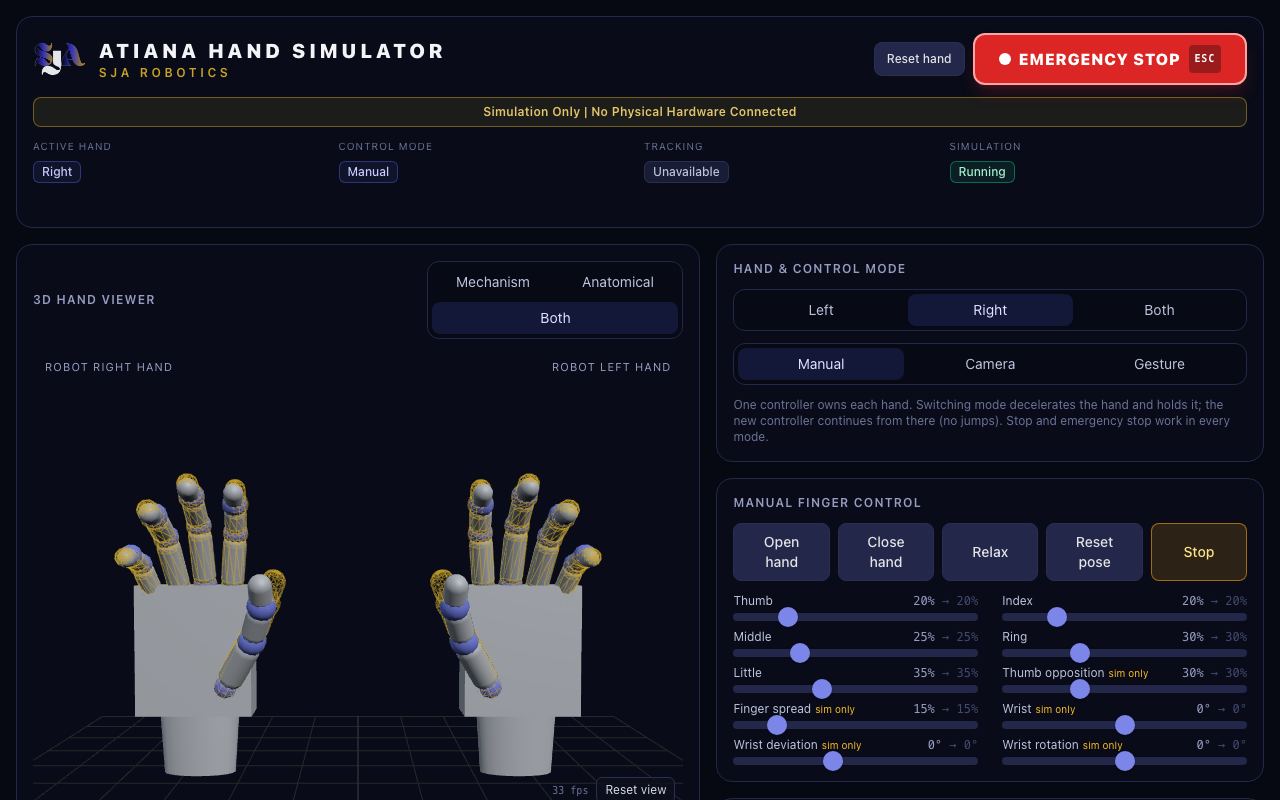
Screenshot of the public ATIANA Hands simulationSimulation · live

ATIANA Hands

Functional prototype

Anatomical two-hand model with bounded, safe finger motion, a gesture library and in-browser camera imitation.

  • Finger flexion sliders for left, right or both hands
  • Ten preset gestures as data, with an honest feasibility report
  • Browser-camera hand imitation, processed in the tab
  • Simulated latched emergency stop and servo telemetry
  • Software (Simulation software): Complete
  • Demo (Public demo): Complete
  • Integration (Integration): In progress
  • Hardware (Hardware validation): Pending

Software verified in simulation. No physical hand, servo or glove has been tested.
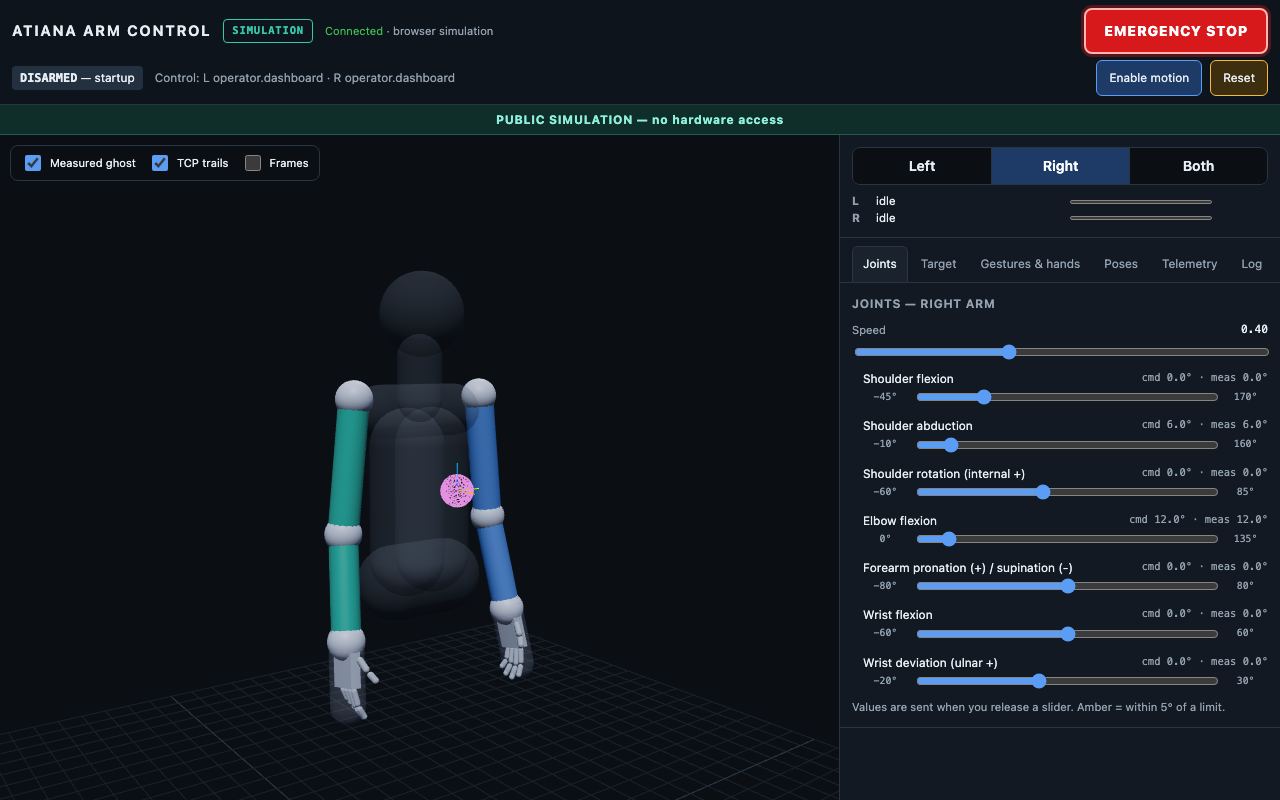
Screenshot of the public ATIANA Arms simulationSimulation · live

ATIANA Arms

In development

Two mirrored 7-DOF arms with forward and inverse kinematics, motion planning, capsule collision checks and a safety supervisor.

  • Damped-least-squares IK with explicit unreachable-target rejection
  • Minimum-jerk and synchronized two-arm motion planning
  • Simplified capsule self-collision checking
  • Thirteen data-defined gestures such as wave and two-arm offer
  • Software (Simulation software): Complete
  • Demo (Public demo): Complete
  • Integration (Integration): In progress
  • Hardware (Hardware validation): Pending

Simulation only. No actuator driver ships yet, and collision checks are not a physical guarantee.

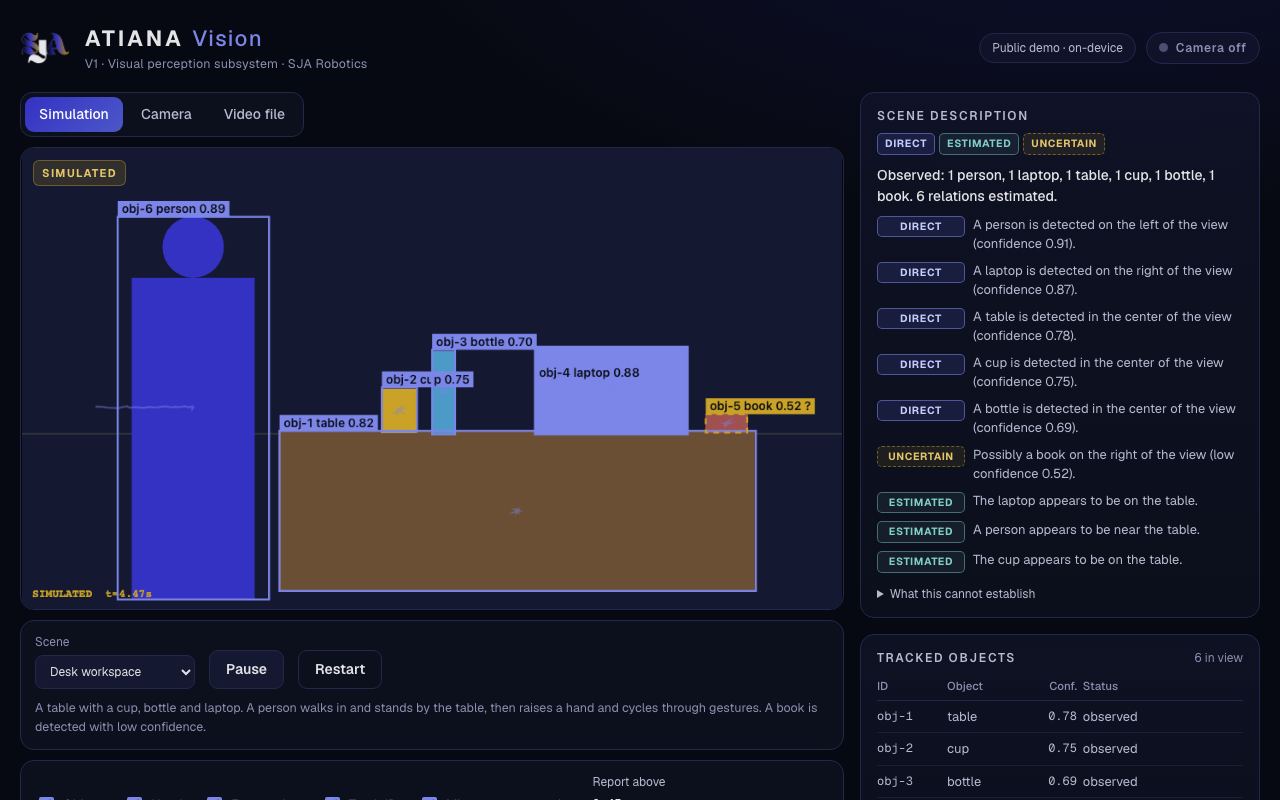
Screenshot of the public ATIANA Vision simulationSimulation · live

ATIANA Vision

In development

Perception-only subsystem: object detection, tracking, hand landmarks, face regions and a scene description that separates detected from estimated.

  • 80-class object detection with uncertainty labels
  • Tracking with stable IDs and occlusion handling
  • Hand landmarks and rule-based gesture recognition
  • Opt-in webcam analysis that never leaves the browser
  • Software (Simulation software): Complete
  • Demo (Public demo): Complete
  • Integration (Integration): In progress
  • Hardware (Hardware validation): Pending

Runs without robot hardware. No physical robot camera has been verified, and it never drives actuators.

Not deployed

ATIANA Core

In development

Central coordination layer: subsystem registry, validated command routing, control authority, safety supervision and deterministic tasks.

  • Subsystem registry and capability discovery
  • Command routing with validation, expiry and cancellation
  • Latched e-stop, arming, watchdog and control leases
  • Recorded end-to-end simulation scenarios
  • Software (Simulation software): Complete
  • Demo (Public demo): Pending
  • Integration (Integration): In progress
  • Hardware (Hardware validation): Pending

Public demo is prepared but not deployed. Hardware bridges are implemented against mocks only.

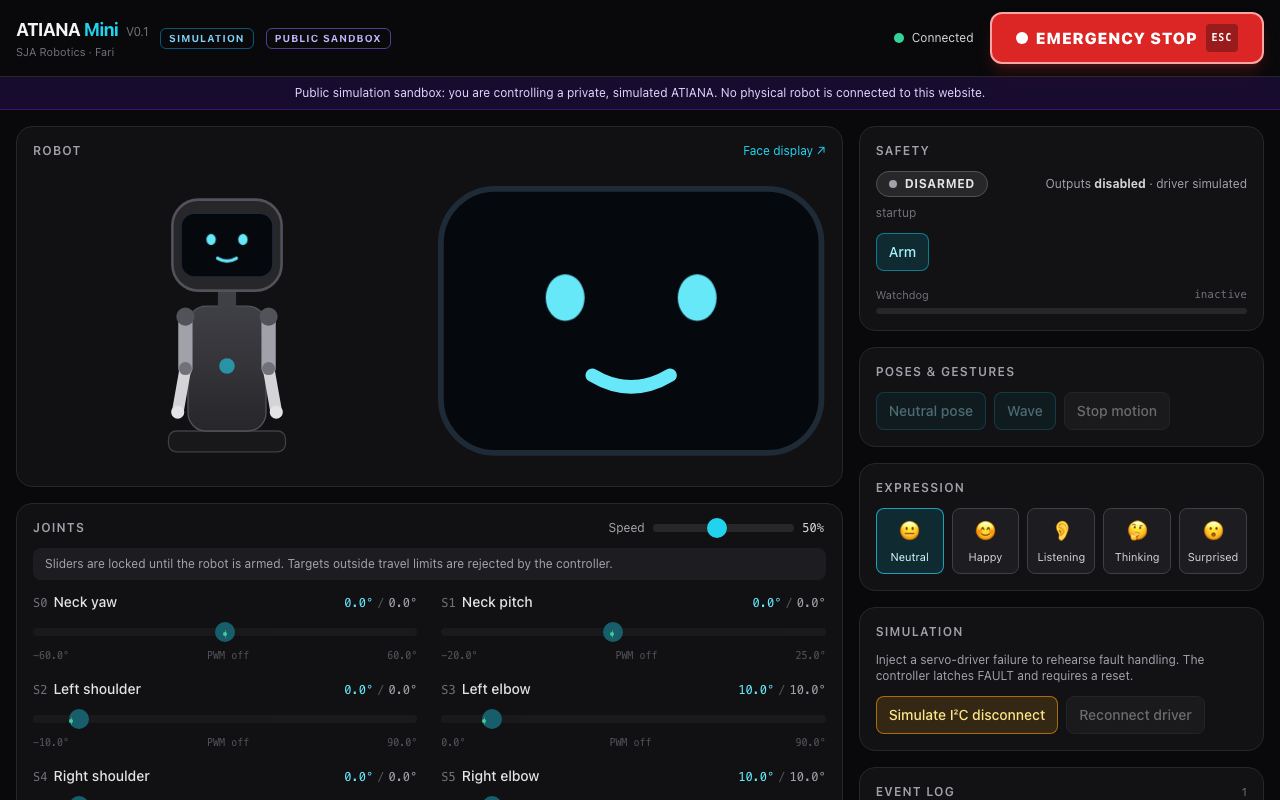
Screenshot of the public ATIANA Mini simulationSimulation · live

ATIANA Mini

In development

A 30 cm desktop humanoid with six servo joints. The public sandbox gives each visitor their own isolated simulated robot.

  • Arm, move joints and wave in a private sandbox
  • Bounded trajectories and a heartbeat watchdog
  • Facial expressions on an animated face
  • Latched emergency stop with deliberate reset
  • Software (Simulation software): Complete
  • Demo (Public demo): Complete
  • Integration (Integration): In progress
  • Hardware (Hardware validation): Pending

Public site is simulation only. Arduino UNO support is awaiting its first physical test. The sandbox backend may take about a minute to wake.

Honest status

Simulation versus physical hardware

What runs today: simulation

  • Every linked demo runs entirely in your browser or in an isolated simulated sandbox.
  • No public page can reach a servo, controller, robot camera or microphone.
  • Camera features in the Hands and Vision demos are opt-in and process video inside your tab.
  • This Virtual Lab only links to those demos. It sends no commands anywhere.

Not yet validated: physical hardware

  • No ATIANA hand, arm, Mini servo or robot-mounted camera has been tested on physical hardware yet.
  • Servo pulse widths, joint limits and wiring are placeholders until parts are built and measured.
  • Software emergency stops are not safety-rated power cutoffs.
  • Private hardware controllers stay on local machines and are never deployed publicly.

Architecture

The ATIANA ecosystem

ATIANA Core is the coordination and safety layer between Fari, ATIANA's intelligence system, and the body subsystems. Today each project integrates through versioned contracts and mocks, not live connections.

Fari

Intelligence system · future integration

Gateway with deterministic mock

ATIANA Core

Coordination · safety · tasks

ATIANA Vision

Perception only

↔ Core: Proposed event contract

ATIANA Arms

Kinematics · motion planning

↔ Core: Core contract 1.1.0 · bridge pending

ATIANA Hands

Fingers · gestures

↔ Core: Bridge built against mocks

ATIANA Mini

Desktop servo humanoid

↔ Core: Bridge built against mocks

Each subsystem is developed and deployed independently. Lines show documented integration contracts, not live connections: the public demos do not talk to each other or to any robot.

Status

Development progress

Stages reflect each project's own documentation. “Integration” is in progress everywhere because contracts exist but no cross-project connection has been verified end to end.

Development stage of each ATIANA project
ProjectSimulation softwarePublic demoIntegrationHardware validation
ATIANA HandsCompleteCompleteIn progressPending
ATIANA ArmsCompleteCompleteIn progressPending
ATIANA VisionCompleteCompleteIn progressPending
ATIANA CoreCompletePendingIn progressPending
ATIANA MiniCompleteCompleteIn progressPending

Next

Integration roadmap

  1. Phase 1Now

    Virtual Lab showcase

    One hub that presents every subsystem, links to its independently deployed simulation and reports status honestly.

  2. Phase 2Planned

    Contract-based embedding

    Consume each project's published, versioned data contracts (for example the hand-control browser model) to show live previews inside the lab.

  3. Phase 3Planned

    Core-coordinated scenarios

    Once ATIANA Core is deployed, replay its recorded simulation scenarios and show event flow across hands, arms, vision and Mini.

  4. Phase 4Future

    Unified virtual ATIANA + Fari

    A single simulated humanoid combining all subsystems, with Fari integrated as a separate, permission-checked intelligence layer.